Skip to content
SPERA Humanoids

Capabilities

Real-world capabilities for real-world impact.

SPERA humanoid robots combine advanced hardware, intelligent control and human-machine coordination to operate in complex environments.

Built to adapt.Designed to serve.

  • Perceive
  • Move
  • Manipulate
  • Interact
  • Operate

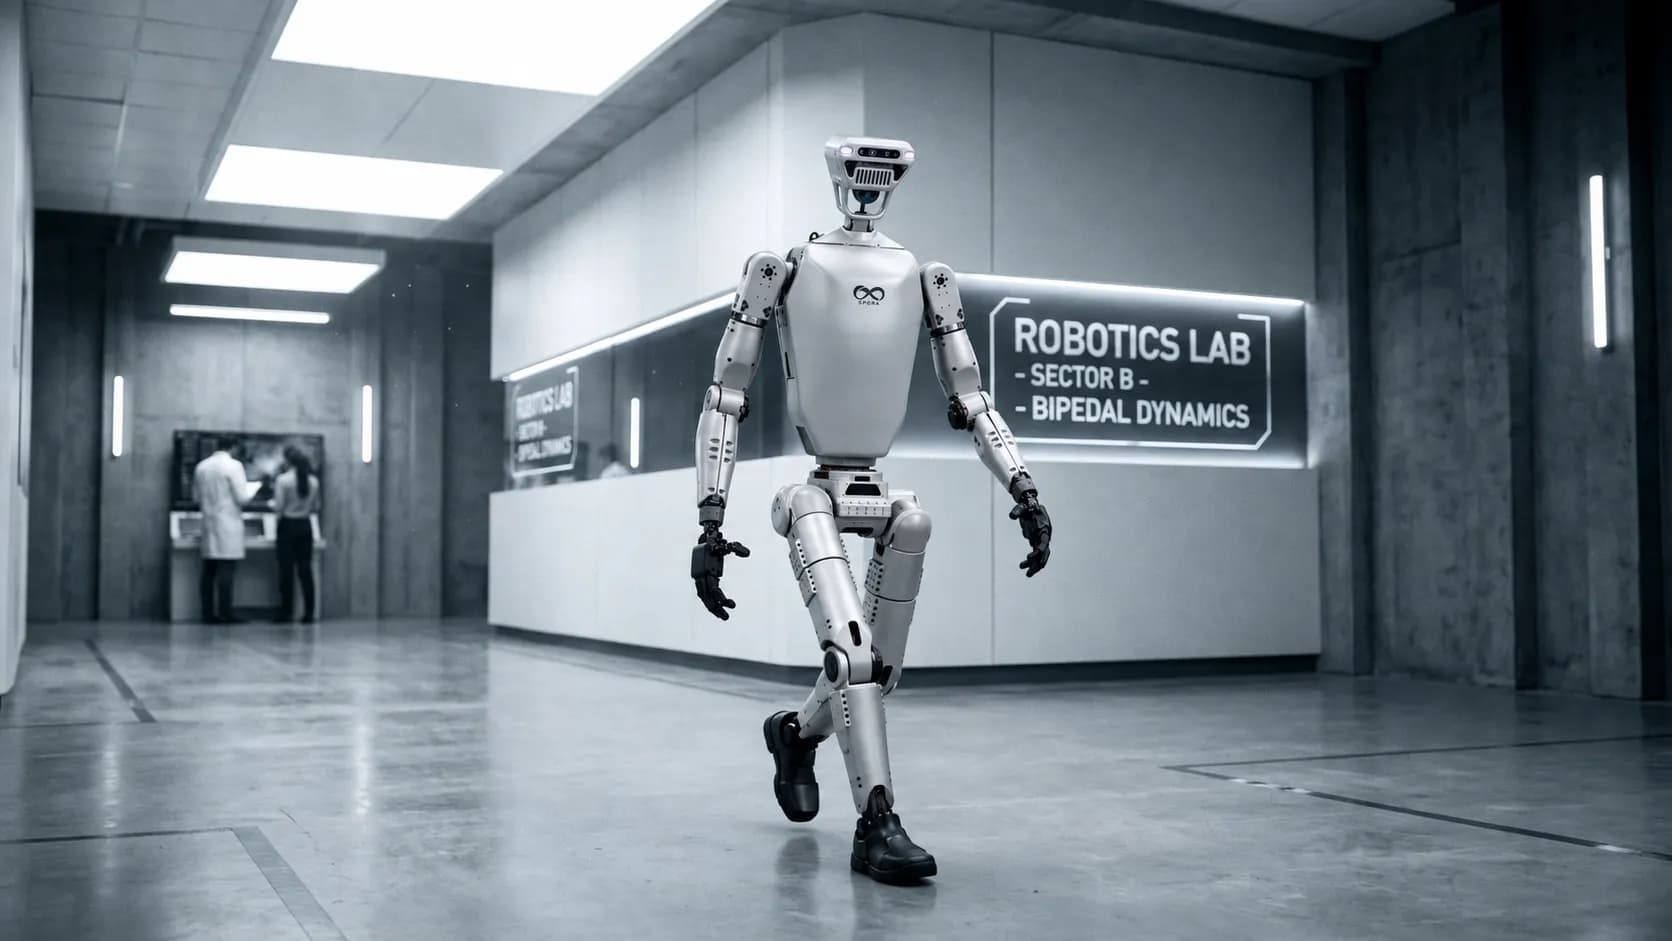
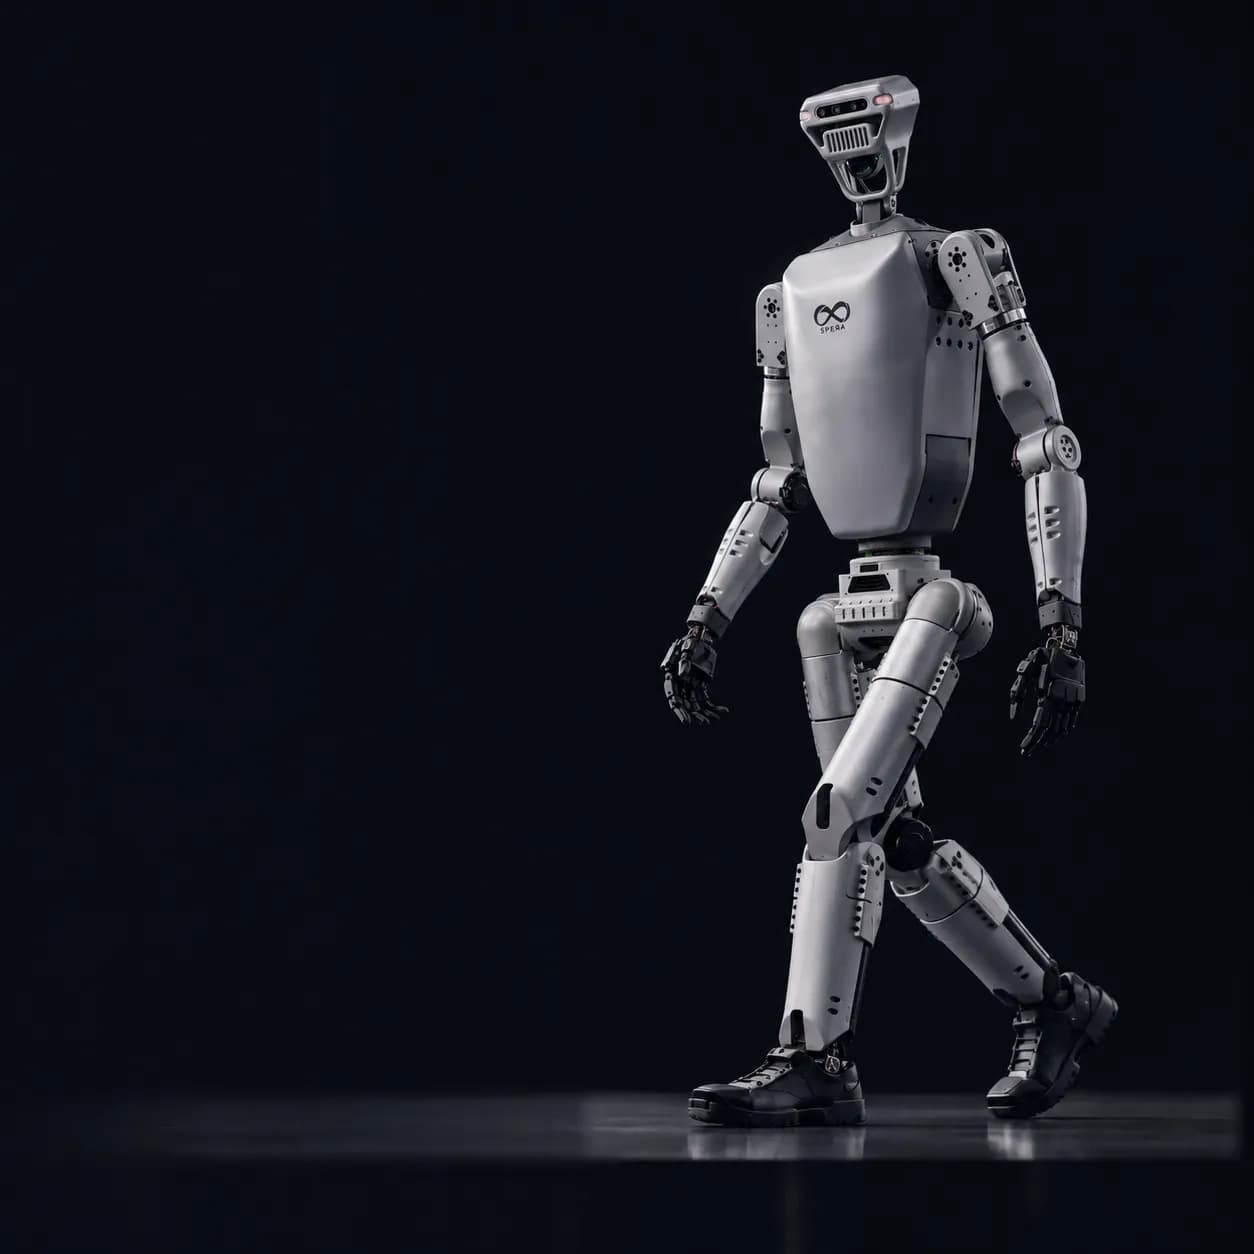
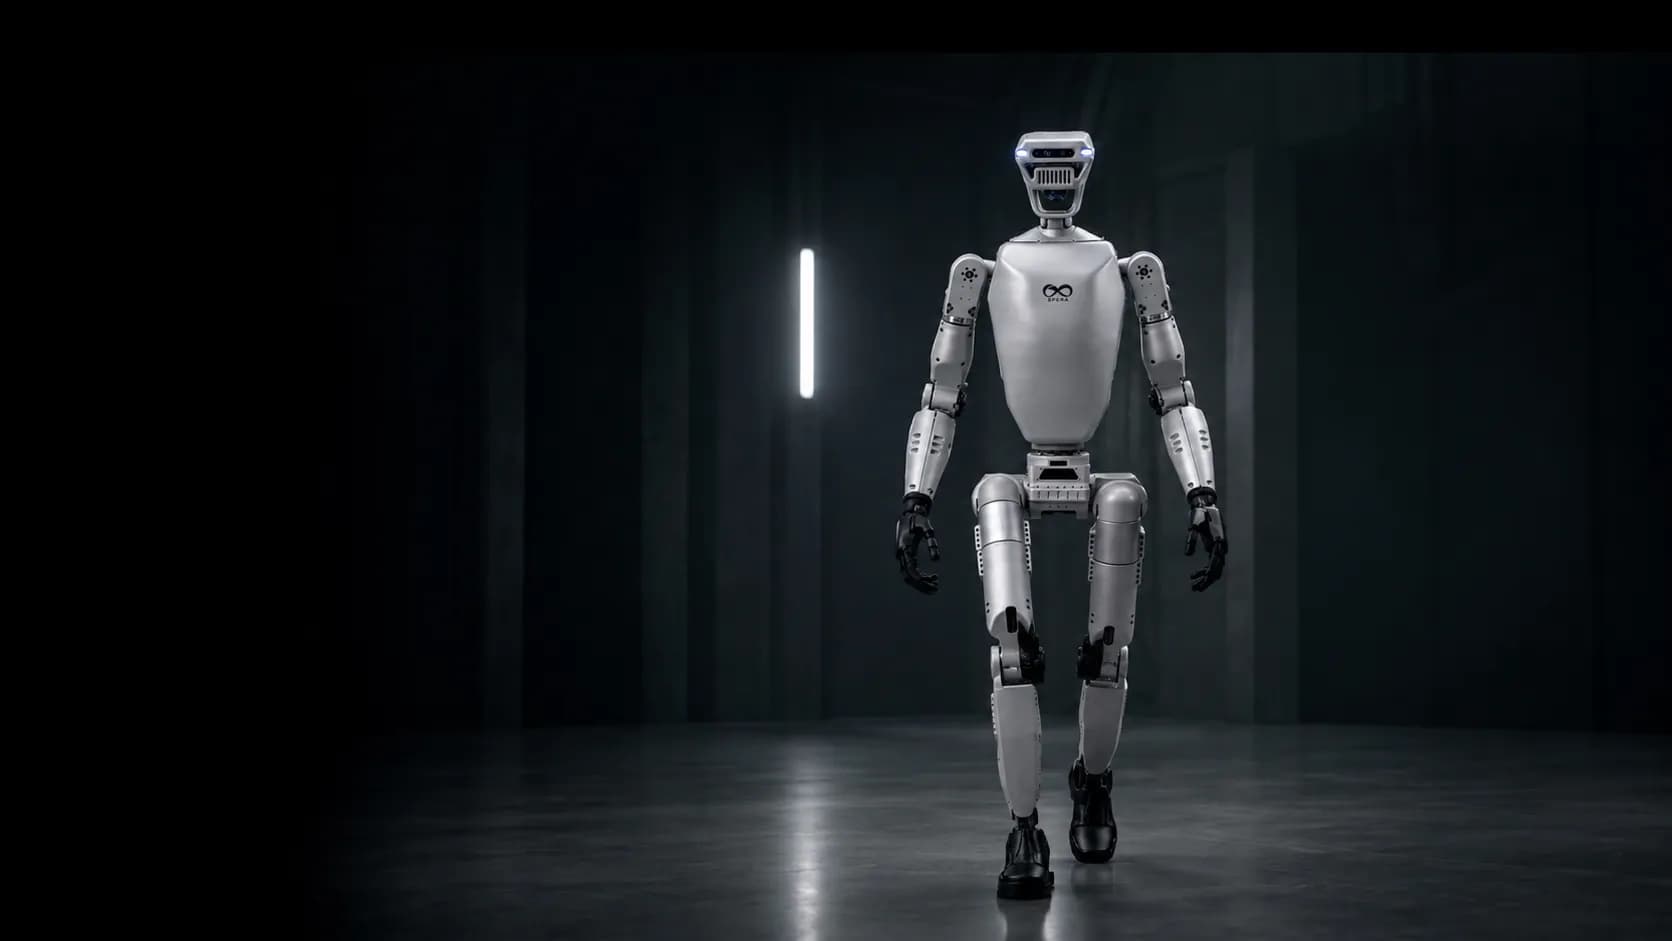
01. Bipedal Locomotion

Stable, adaptable and human-like movement in real-world environments.

  • Forward walking
  • Backward walking
  • Lateral movement
  • Turning
  • Posture control
  • Disturbance rejection
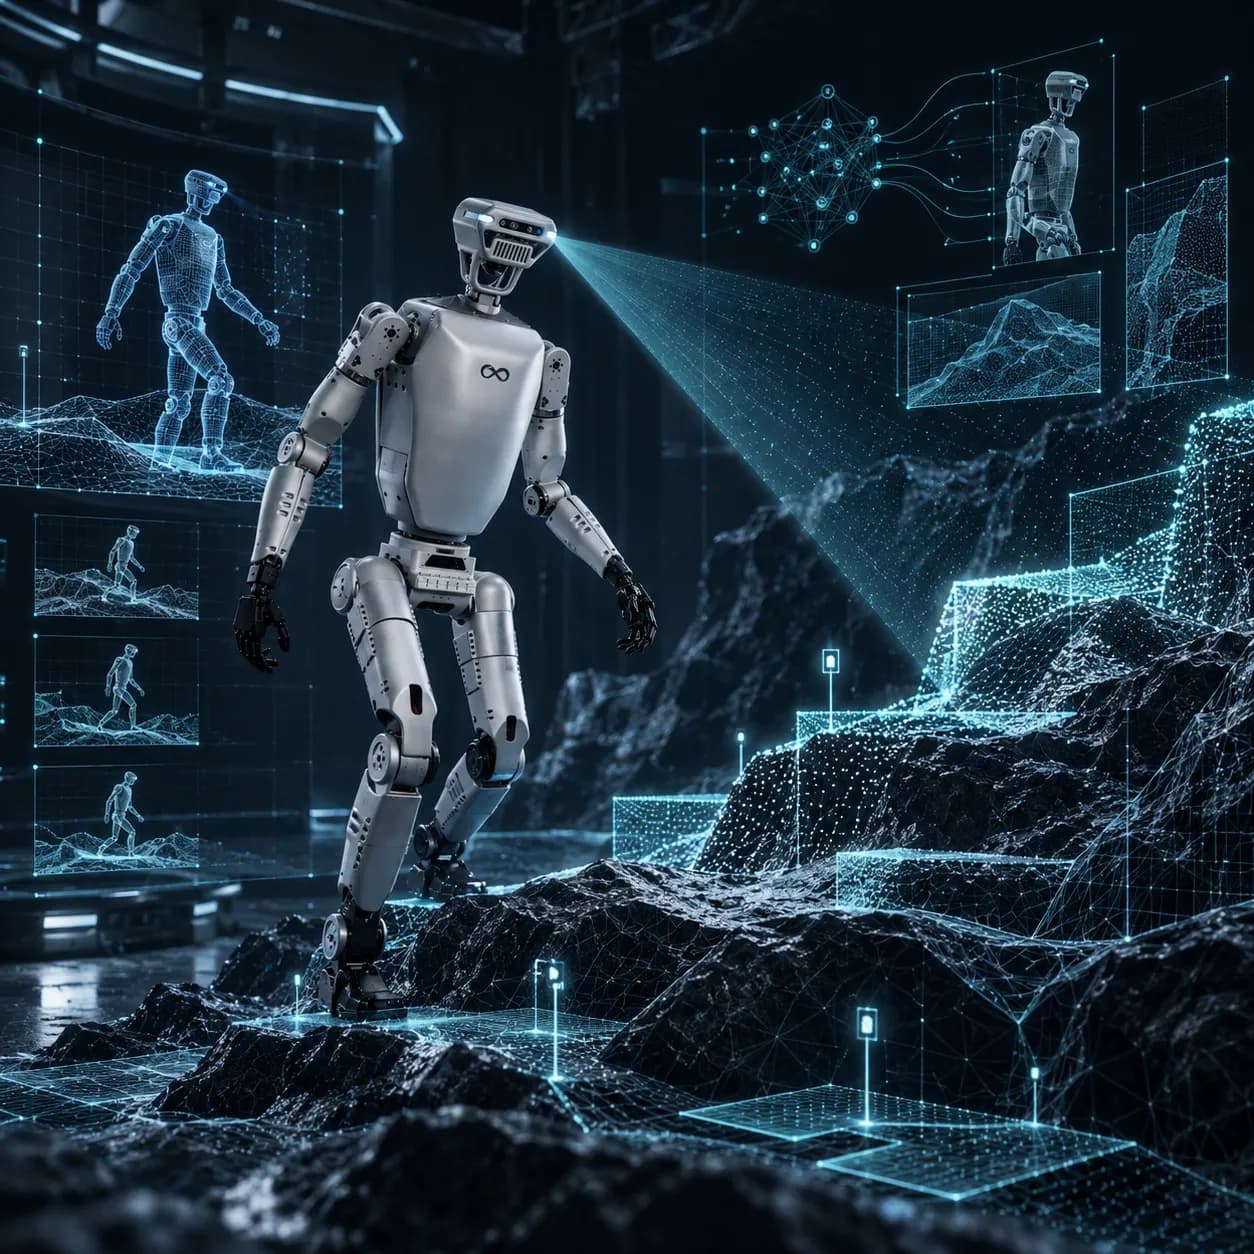
SPERA Bipedal Locomotion Corridor Walking
▶ Bipedal Locomotion01:45

AdaptiveBalanceDynamicStability

Dynamic Stability Gait Profile

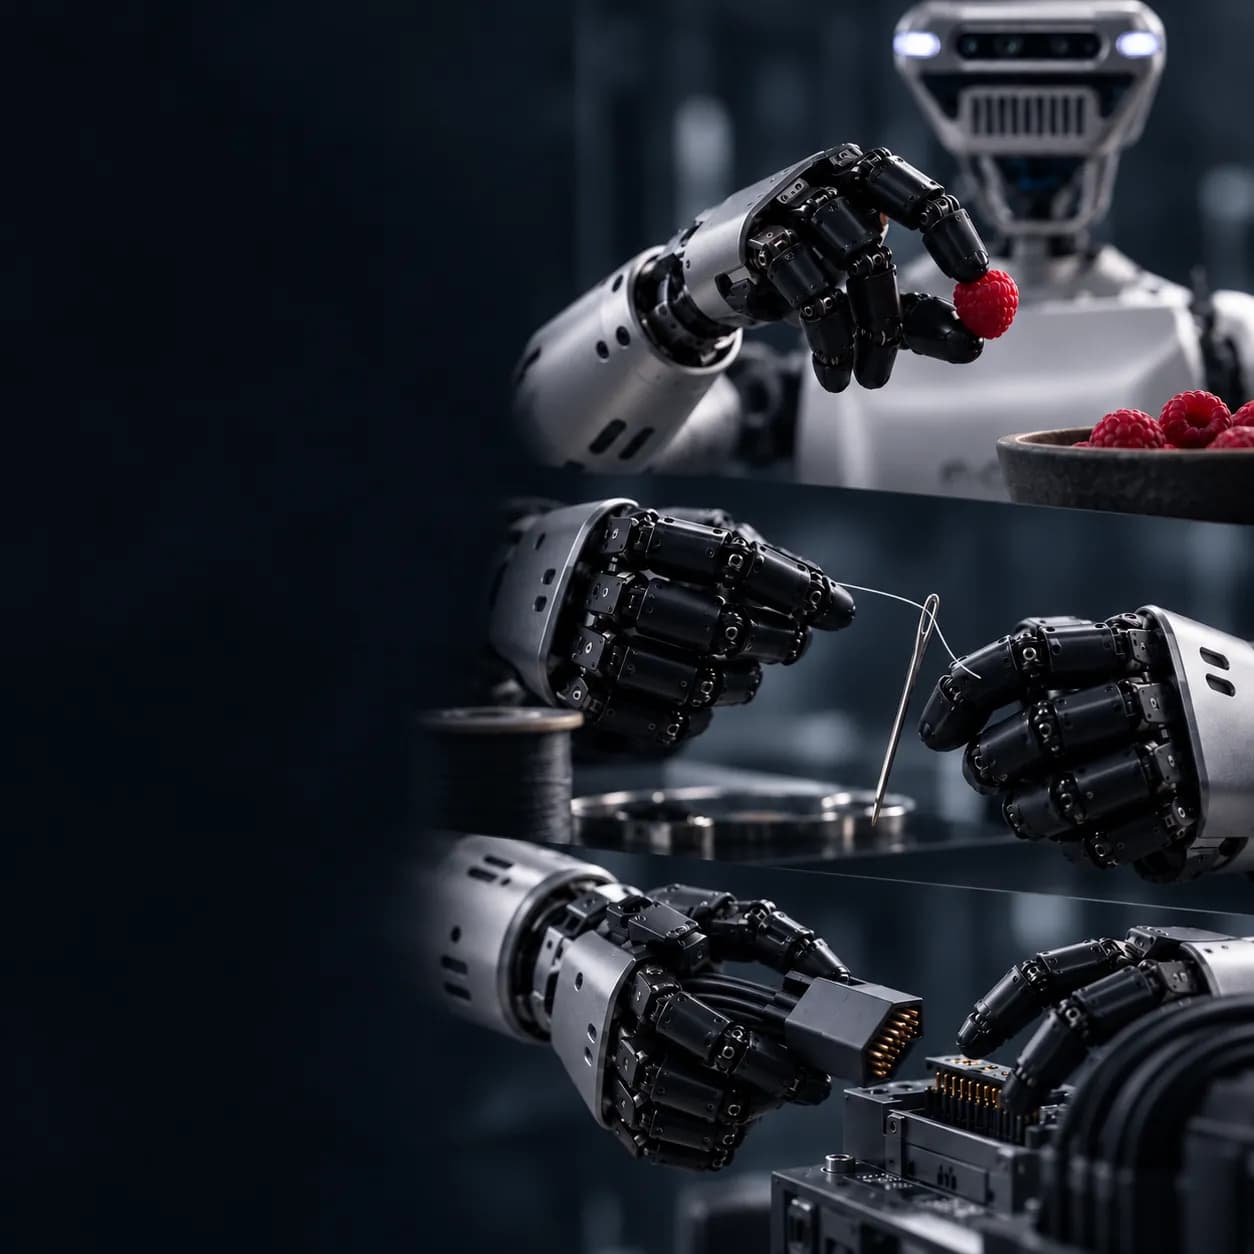
02. Manipulation & Dexterity

Advanced manipulation for real-world tasks using human-inspired dexterity.
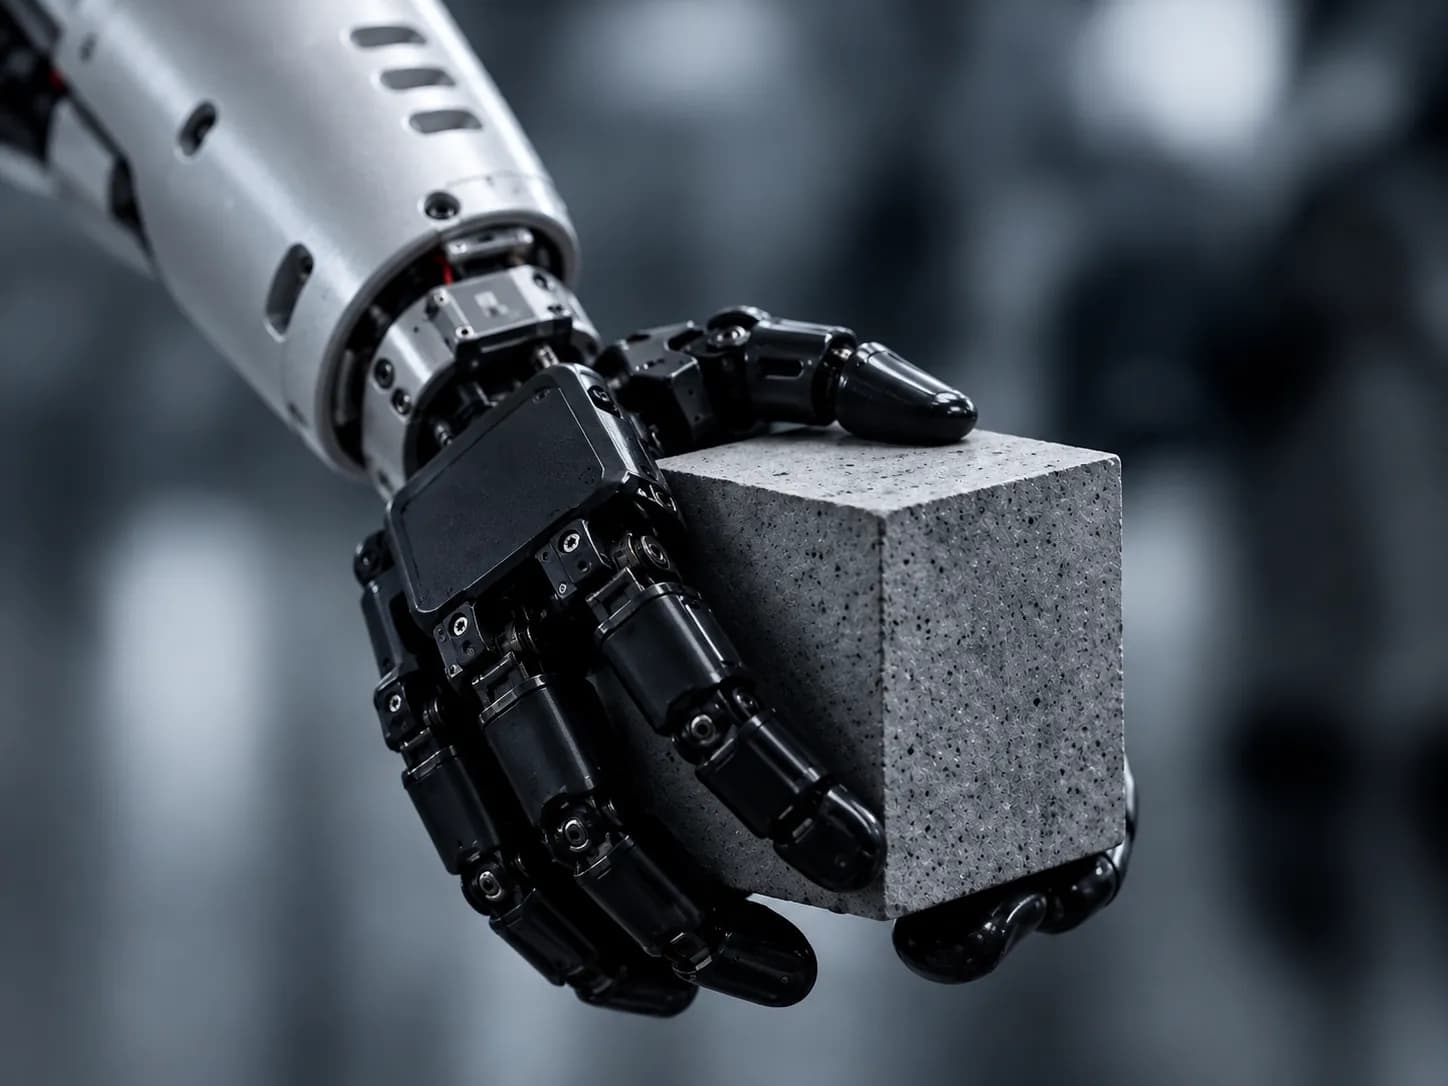
  • Multi-DOF arms
  • Five-finger hands
  • Object handling
  • Open/close doors
  • Tool use (in development)
SPERA Robot Hand Holding Object
▶ Dexterous Manipulation01:32

Human-LevelDexterityForReal Tasks

Articulated Hand Dexterity Reach

03. Perception & Awareness

A rich sensing suite to understand and navigate the physical world.
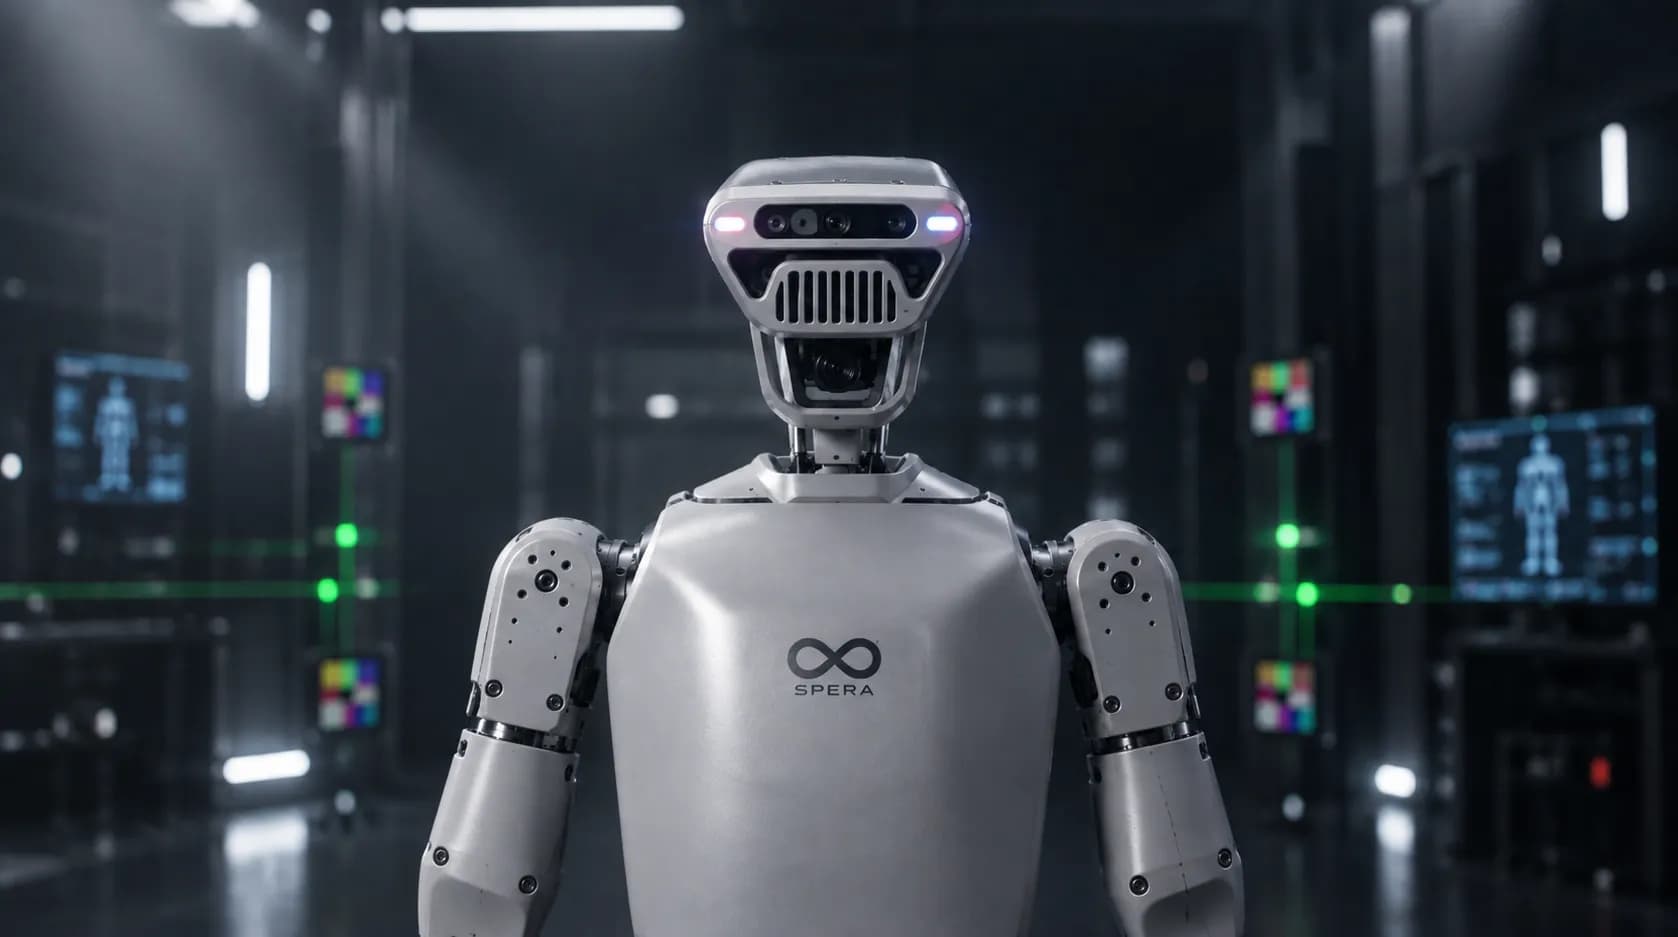
  • LiDAR + depth cameras
  • 3D perception
  • Microphones
  • Environmental awareness
  • Tool uses sensing
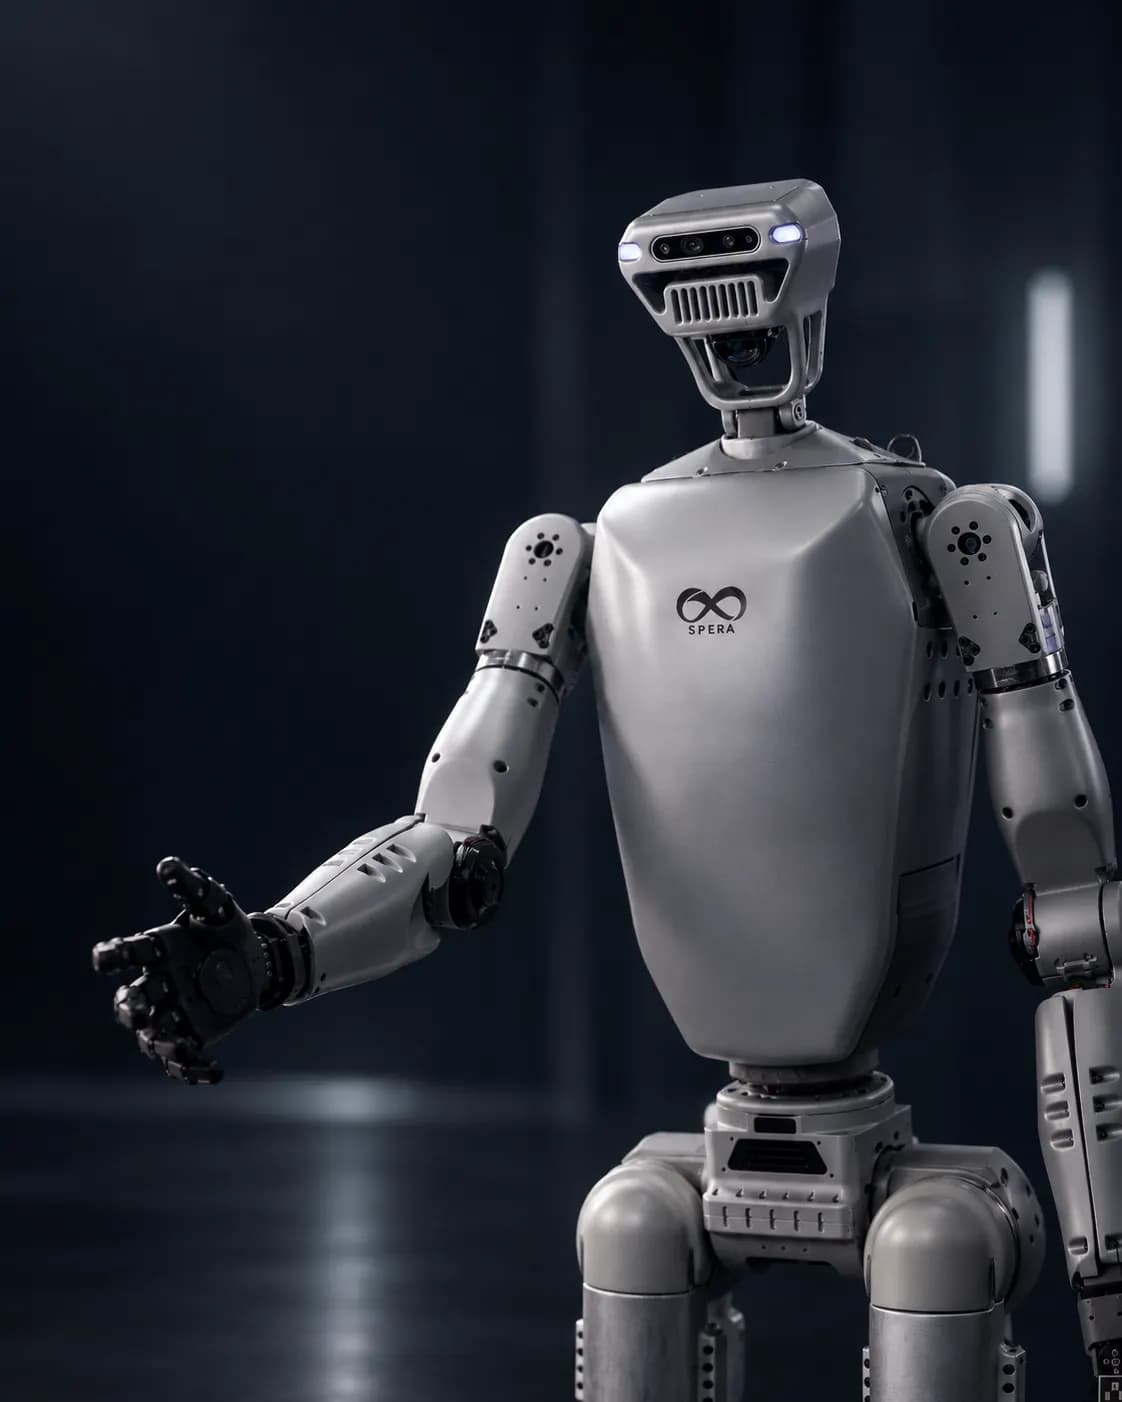
SPERA Perception Optical Visor Array
▶ 3D Spatial Perception01:58

SeeUnderstandAdapt

Point Cloud Spatial LiDAR Mapping

04. Human-Robot Interaction

Designed to work alongside people in real environments.
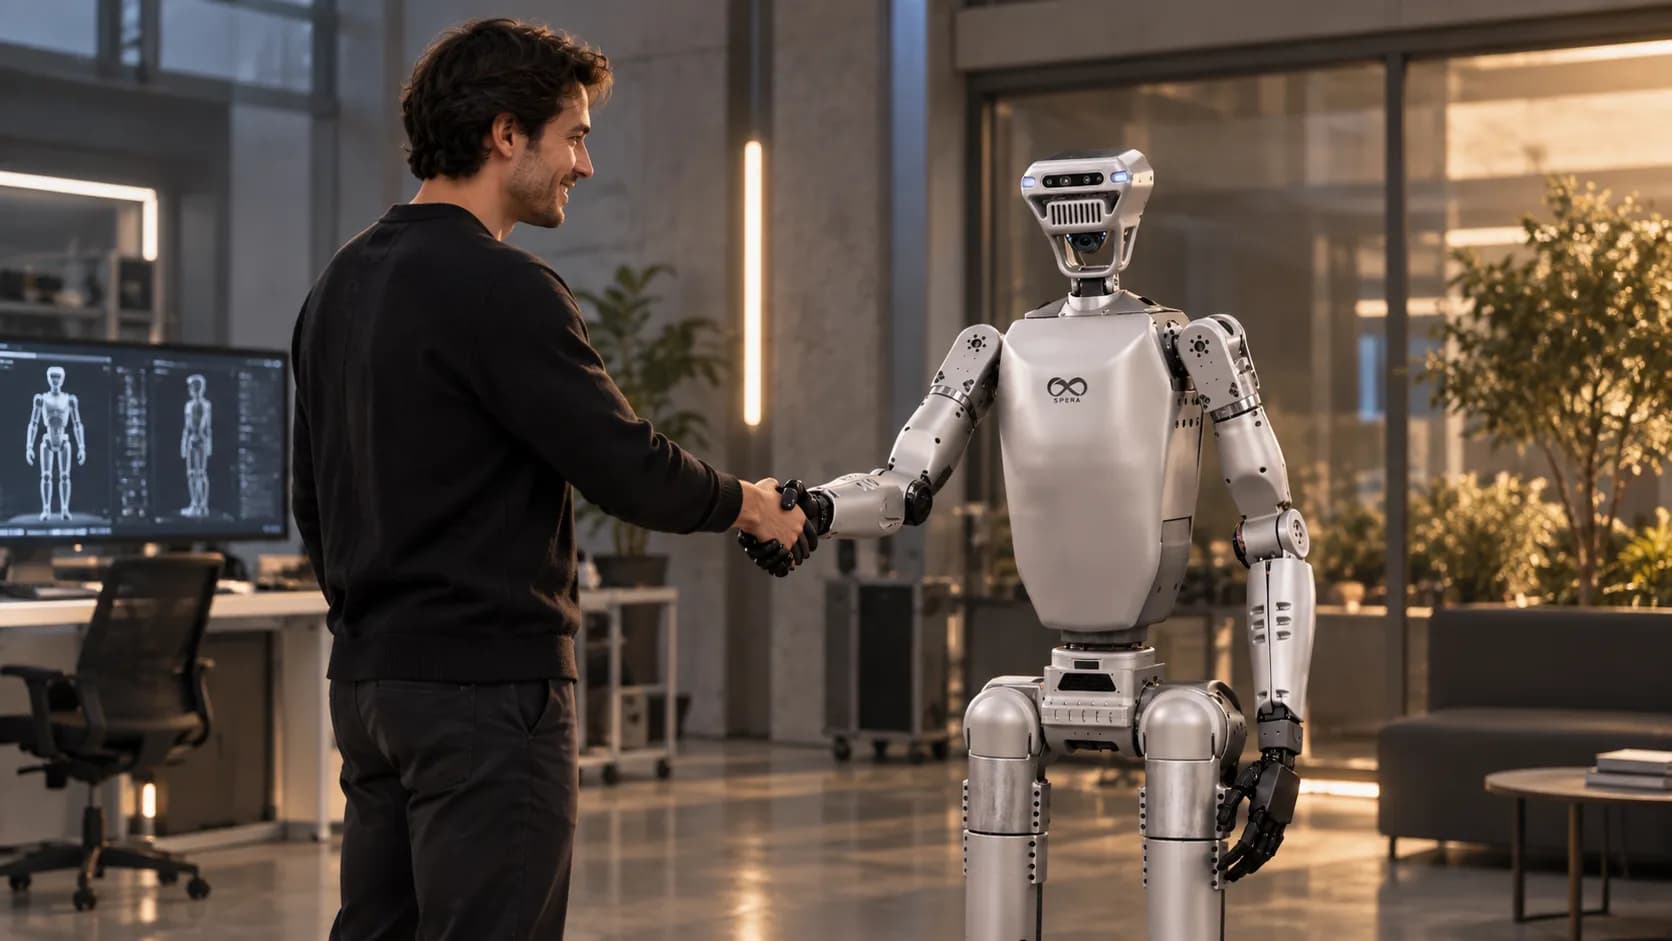
  • Head rotation (360°)
  • Gestures and expressions
  • Natural interaction
  • Sit and interact
  • Designed for human environments
SPERA Robot Expressive Interaction & Gesture
▶ Social & Collaborative Interaction01:25

NaturalIntuitiveHuman-Centric

Intuitive Sensor Visor Profile

05. Teleoperation

Long-range, low-latency control for critical operations.
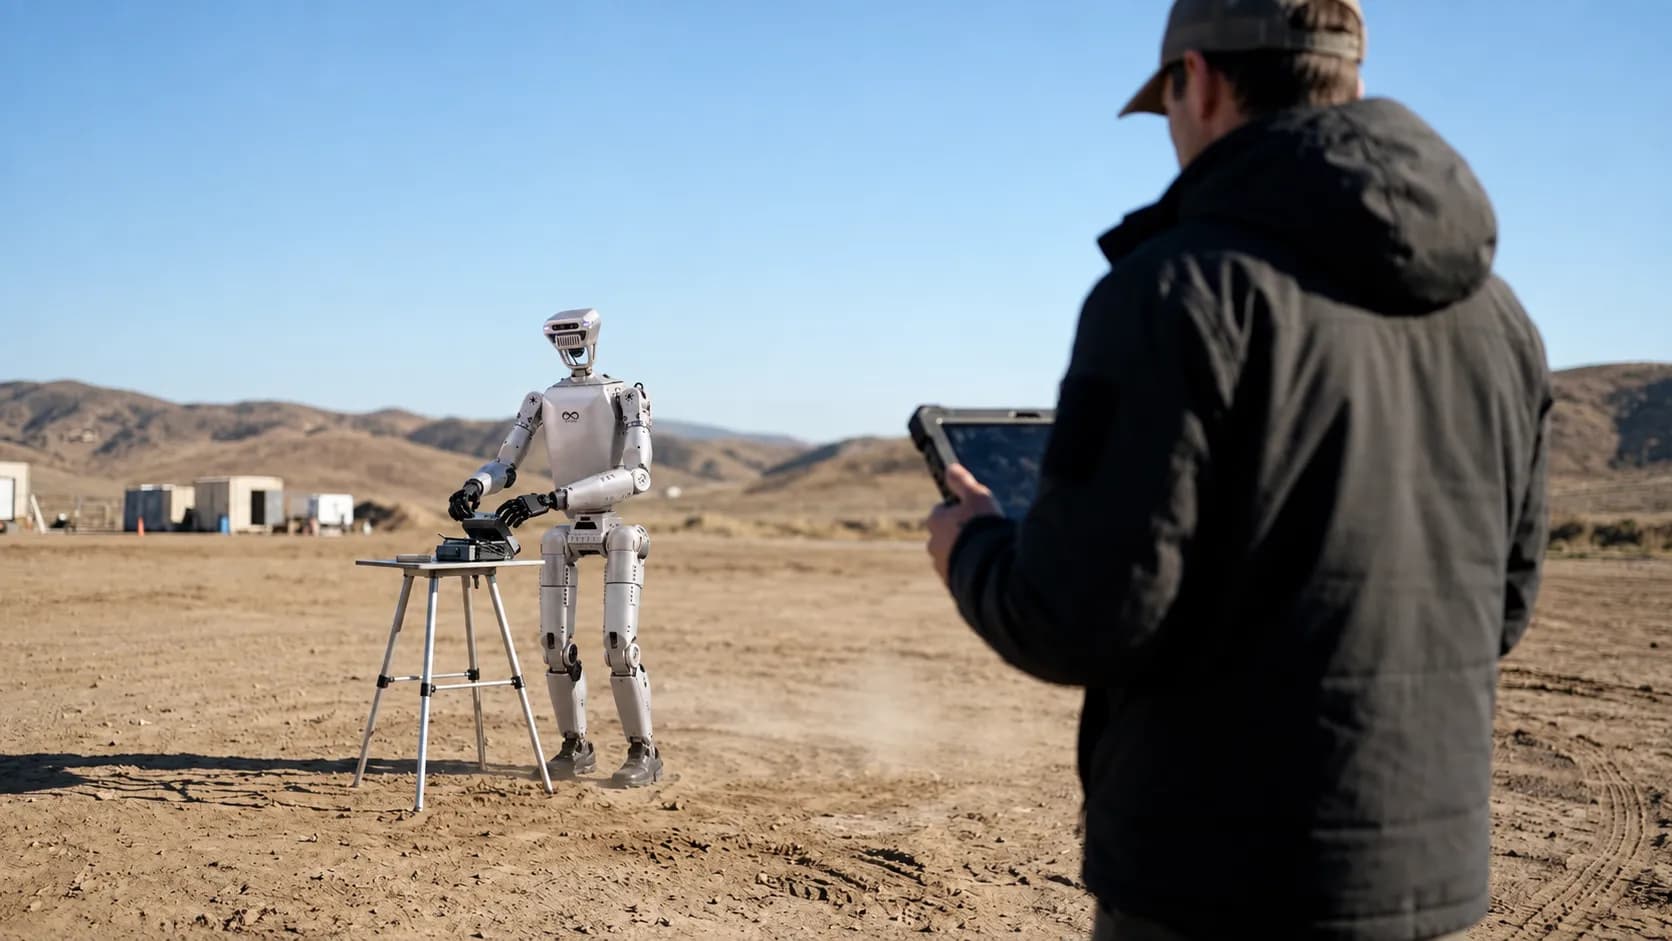
  • Direct RF (no internet)
  • Up to 35 km range
  • Real-time control
  • Reliable and secure
  • Human-robot force multiplier
Operator Teleoperating SPERA Robot Across Field
▶ Field Teleoperation Link02:15

Extended ReachGreater Impact

35 kmDirect RF
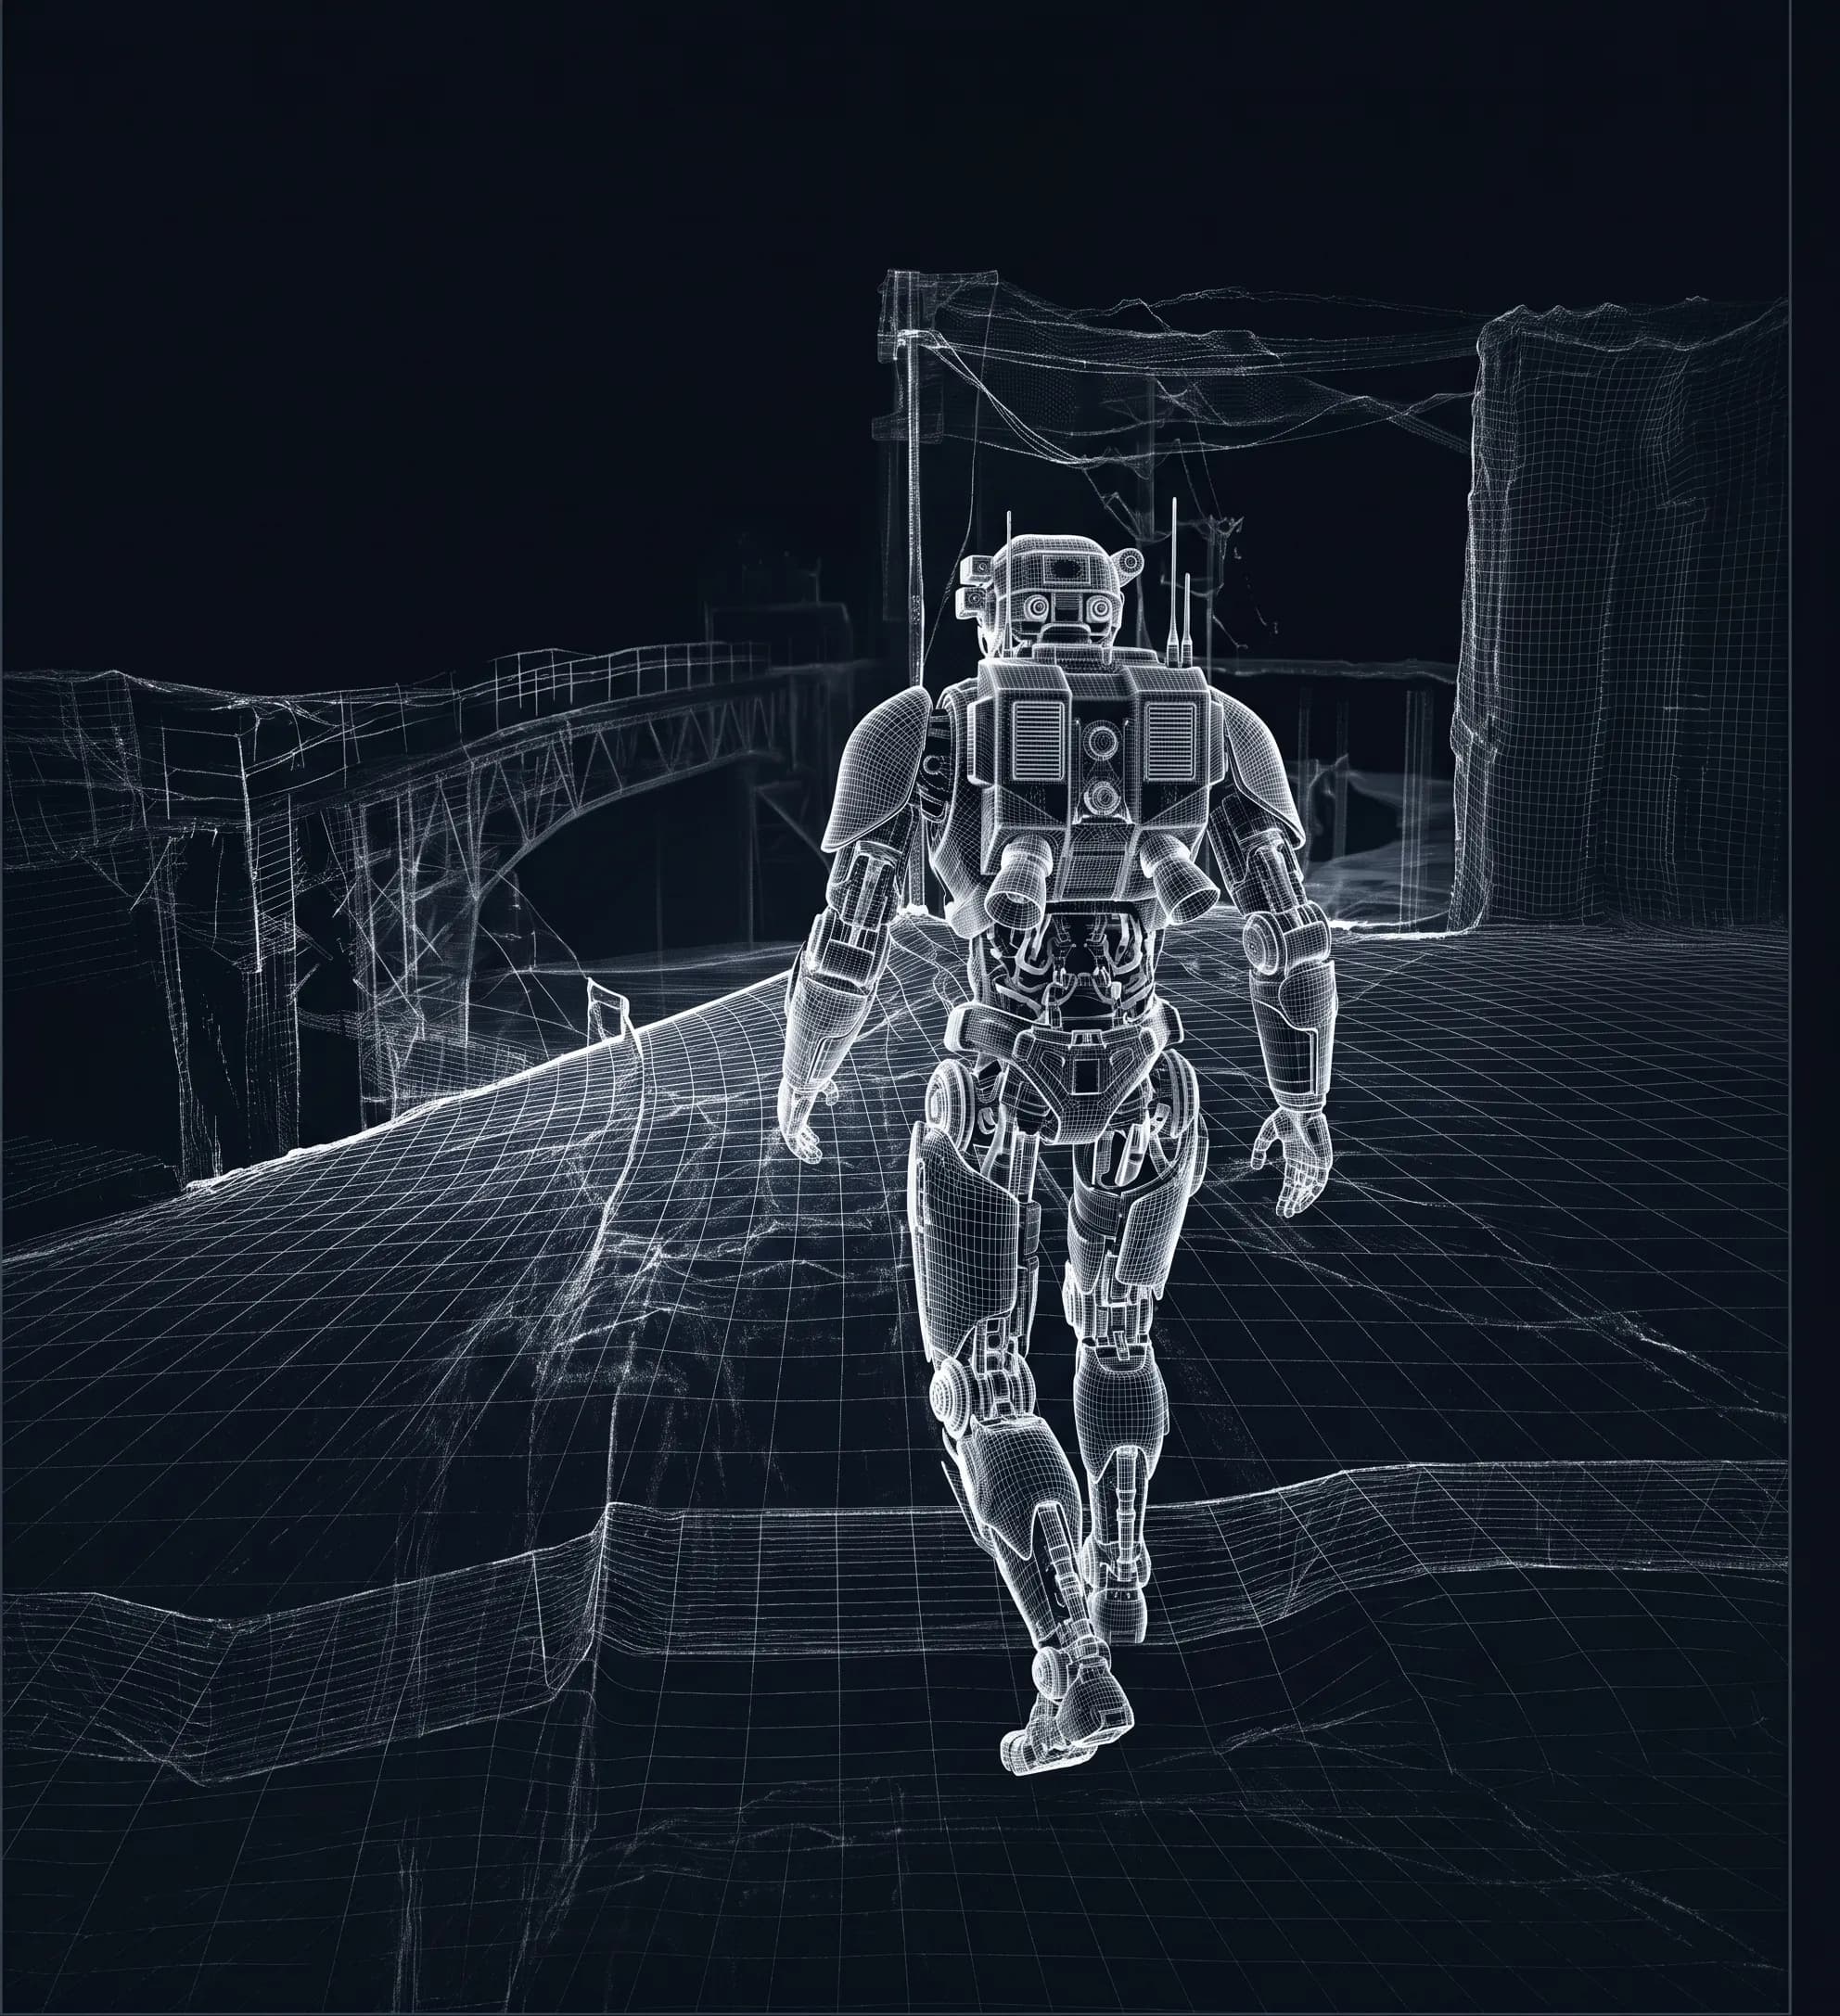
Point Cloud Teleoperation RF Range

How the Platform Operates

Human-supervised. Mission-driven.

  1. 01

    Mission Assignment

    An operator issues a task or patrol objective.

  2. 02

    Movement

    AM-01 navigates the assigned area on foot.

  3. 03

    Observation

    Onboard sensors collect environmental data in real time.

  4. 04

    Decision Support

    Onboard systems assist in interpreting what is seen.

  5. 05

    Operator Control

    A human operator intervenes and takes control when needed.

  6. 06

    Review

    Events are recorded for analysis and after-action review.
“A platform that extends human capability.”

Real capabilities.
A more capable tomorrow.

  • People
  • Safer Environments
  • Greater Possibilities